Fall 2026 course workspace
CSBP441 Applied Computer Vision
Move from visual measurements to meaningful decisions through hand calculation, Python implementation, result analysis, and real-system interpretation.
- Current collection
- LN1-LN13
- Practice modes
- Quiz + generated problems
- Notebook workflow
- Open in Colab
Lecture notes
Learn, calculate, implement
Each lecture page connects the essential theory to a small hands-on task, a notebook, self-check questions, and parameterized exam practice.
 LN1
Computer Vision Foundations
Goals, semantic gap, challenges, applications, and system thinking.
Open lecture LN2
Images, Perception, and Tasks
Digital images, color, pipelines, and the outputs of core vision tasks.
Open lecture LN3
Linear Algebra and Transformations
Vectors, matrices, homogeneous coordinates, and geometric transforms.
Open lecture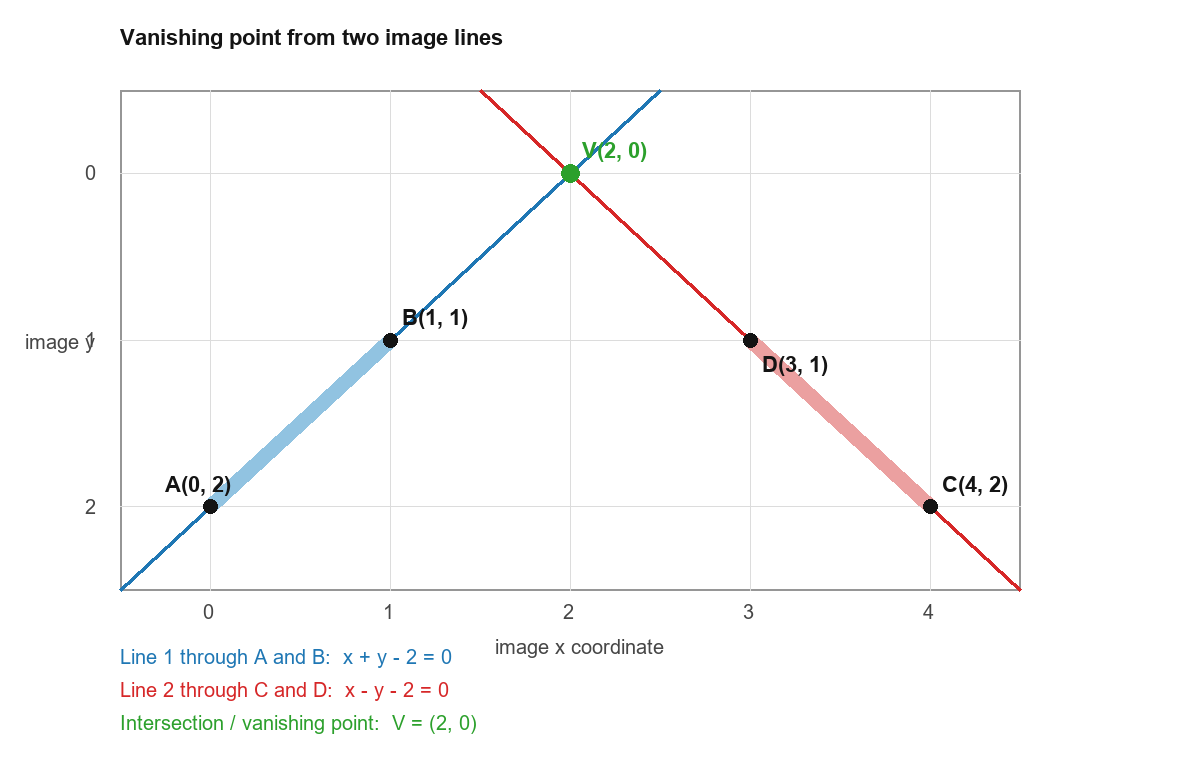 LN4
Camera Models and Projection
Pinhole projection, lines, vanishing points, calibration, and distortion.
Open lecture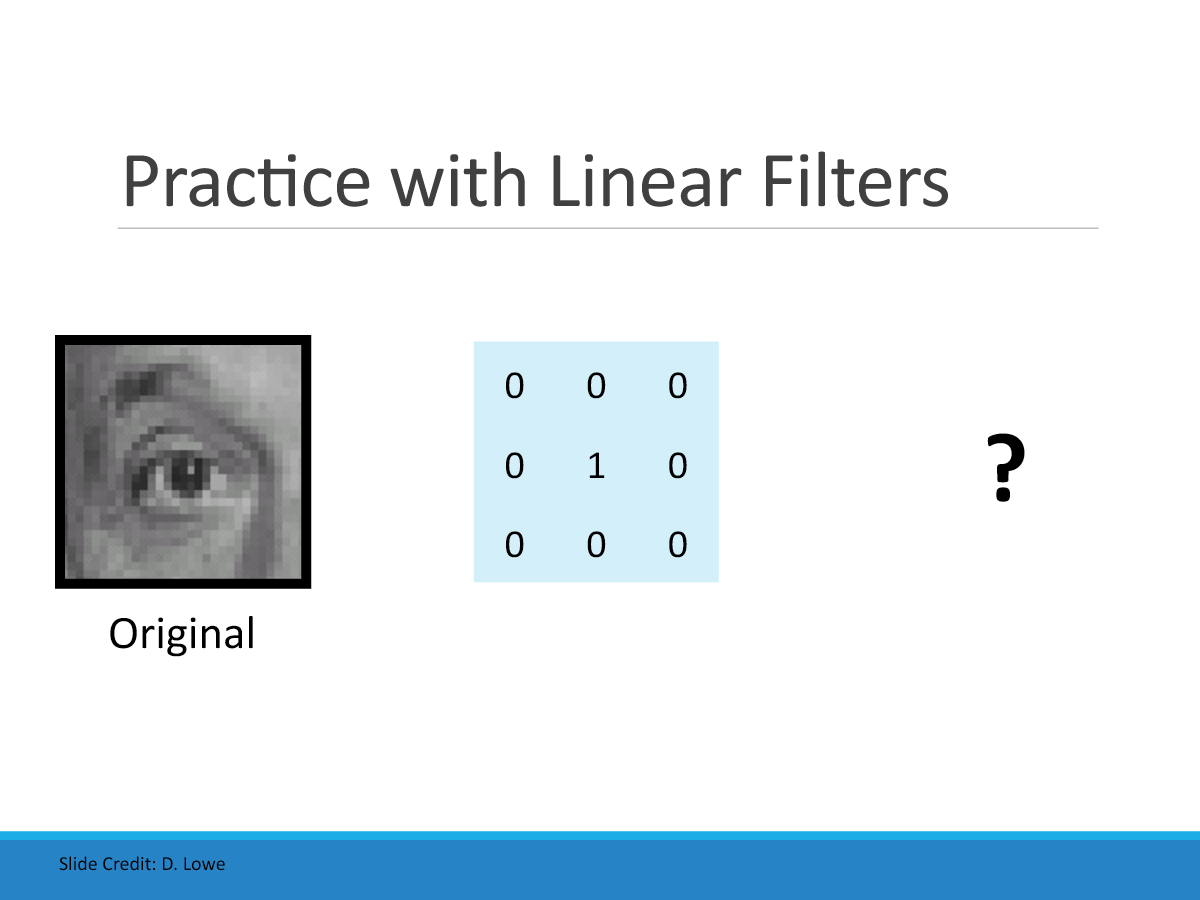 LN5
Images and Filtering
Point operations, correlation, convolution, padding, noise, and edges.
Open lectureLN6Edge Detection and Boundary Analysis
Gradients, Sobel, Laplacian methods, Canny, tuning, and practical evaluation.
Open lecture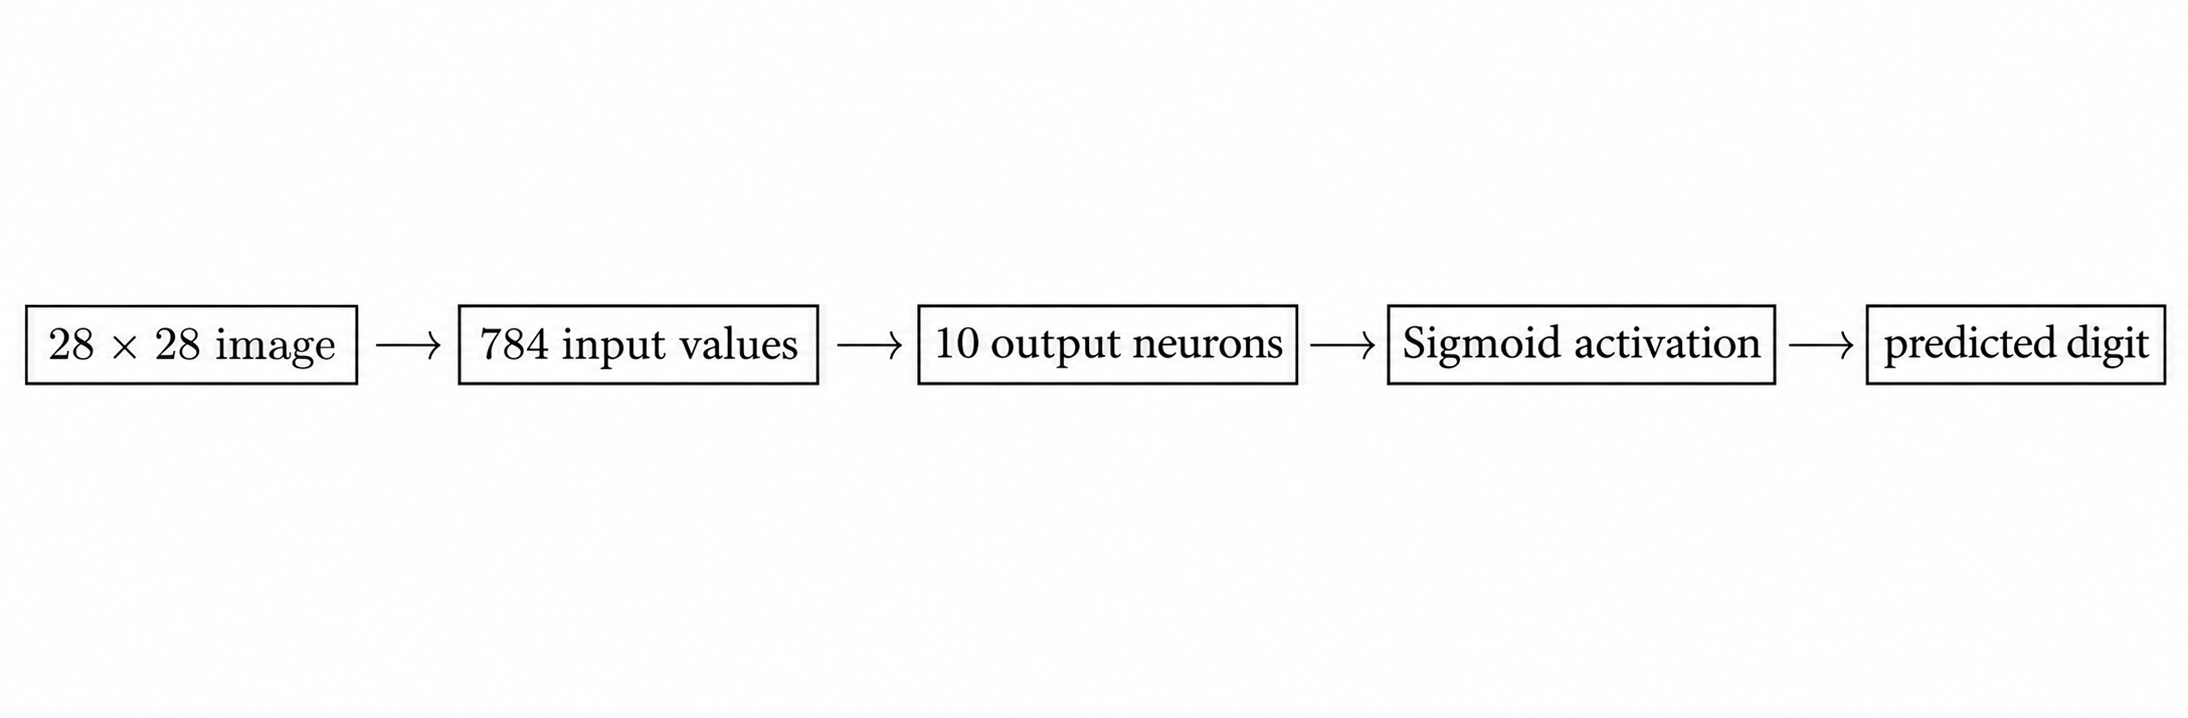 LN7
Neural Networks
Perceptrons, activations, softmax, cross-entropy, training, and classification evaluation.
Open lecture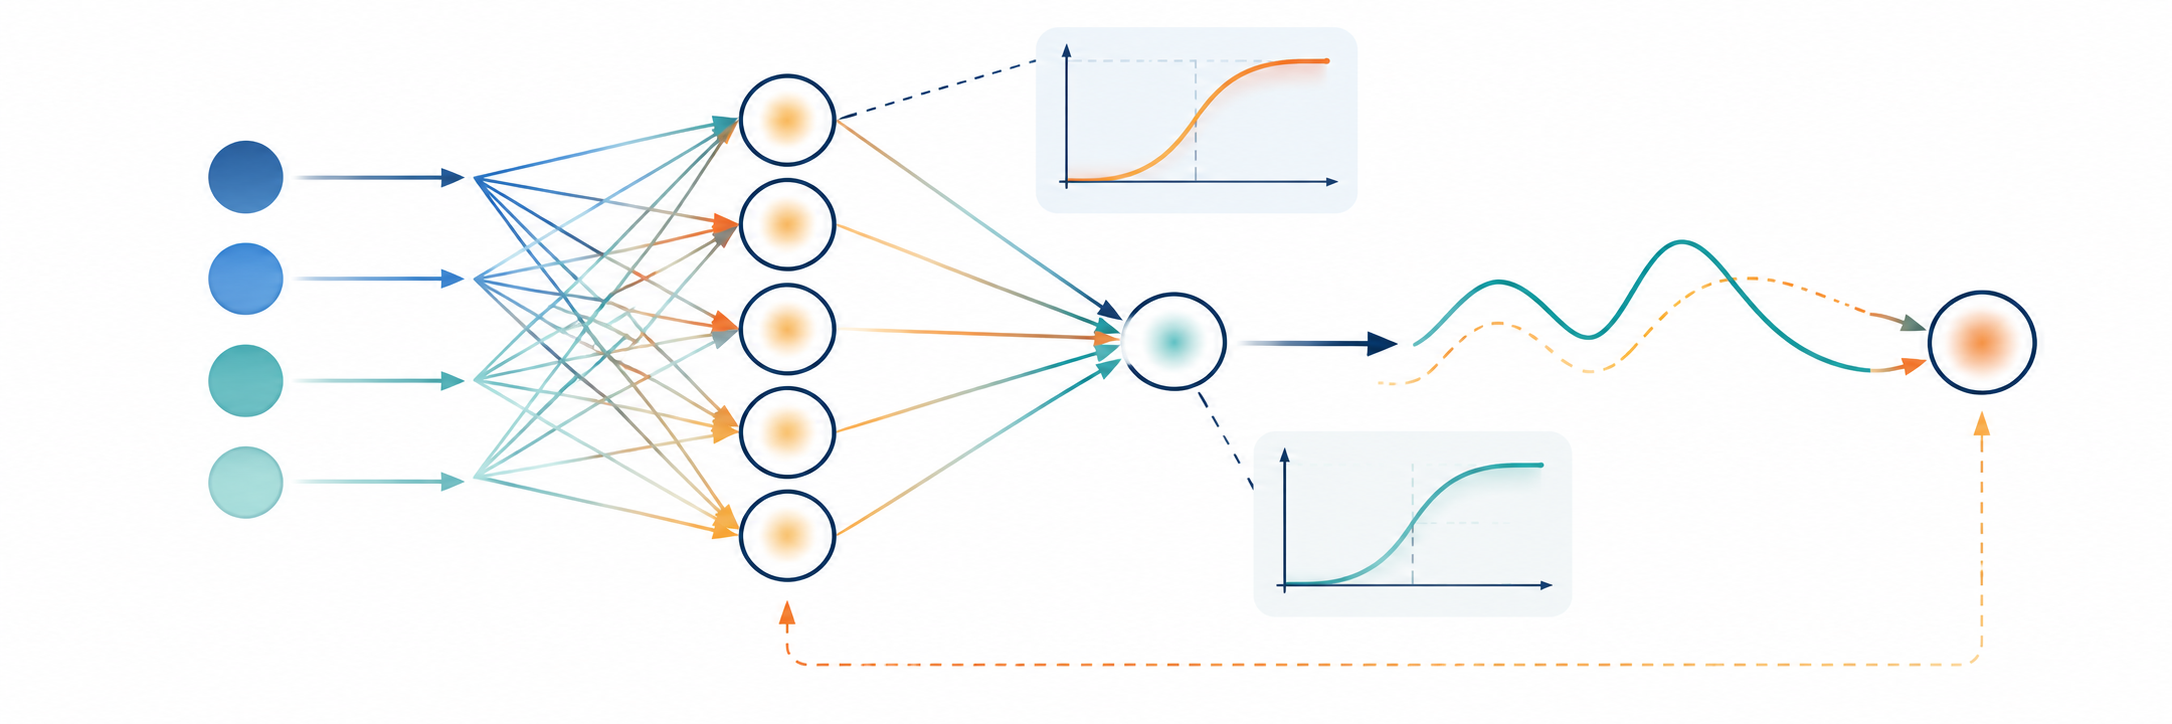 LN8
MLP Training
Forward propagation, sigmoid activations, XOR, backpropagation, and gradient-descent updates.
Open lecture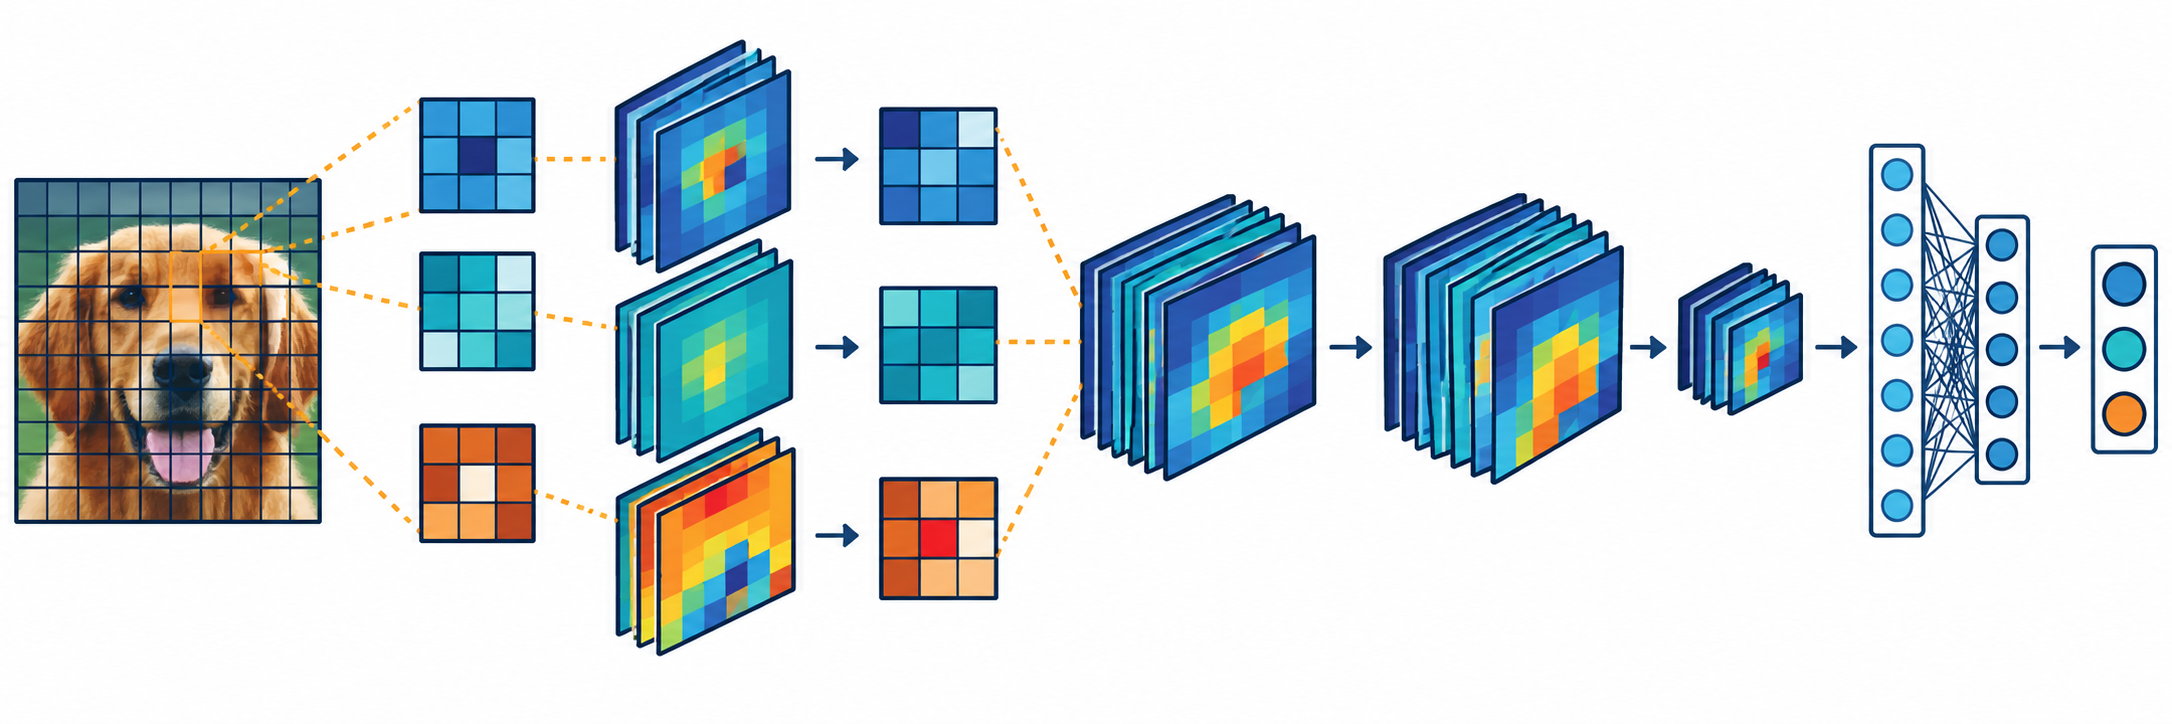 LN9
Convolutional Neural Networks
Convolution, filters, receptive fields, stride, padding, pooling, normalization, LeNet, and AlexNet.
Open lecture LN10
Object Recognition and SIFT
Template matching, interest points, scale-space blobs, orientations, descriptors, and feature matching.
Open lecture LN12
YOLO Object Detection
One-pass detection, grid cells, bounding boxes, confidence, IoU, filtering, and NMS.
Open lecture LN13
U-Net Image Segmentation
Encoder–decoder features, up-convolution, skip connections, 1×1 output scores, and pixel-wise loss.
Open lecture LN11
Corner Detection
Image gradients, second-moment matrices, eigenvalues, Harris response, and non-maximal suppression.
Open lecturePractice engine
One concept, many valid variants
Choose a lecture
Work inside the concept you are currently studying.
Generate a seed
Receive new values while preserving the intended method and difficulty.
Reveal the solution
Compare your method only after completing the calculation.
Course resources
Assessment and notebook material
Class tools
Attendance check-in
Preview roster upload, rotating class codes, student verification, and attendance export in a browser-only demonstration.